Heavy-lift multirotors on ArduPilot
The 17–54″ class is tuned differently from a racing quad: ArduPilot has an official parameter table by propeller size, INAV has none at all — only community experience up to 16″. We migrated a heavy hexa from INAV to CubeOrange+ and ArduPilot 4.7.1 and know where it breaks: parameter names change between firmware versions, the loader silently skips an unknown name, and “file applied” only means “file read”.
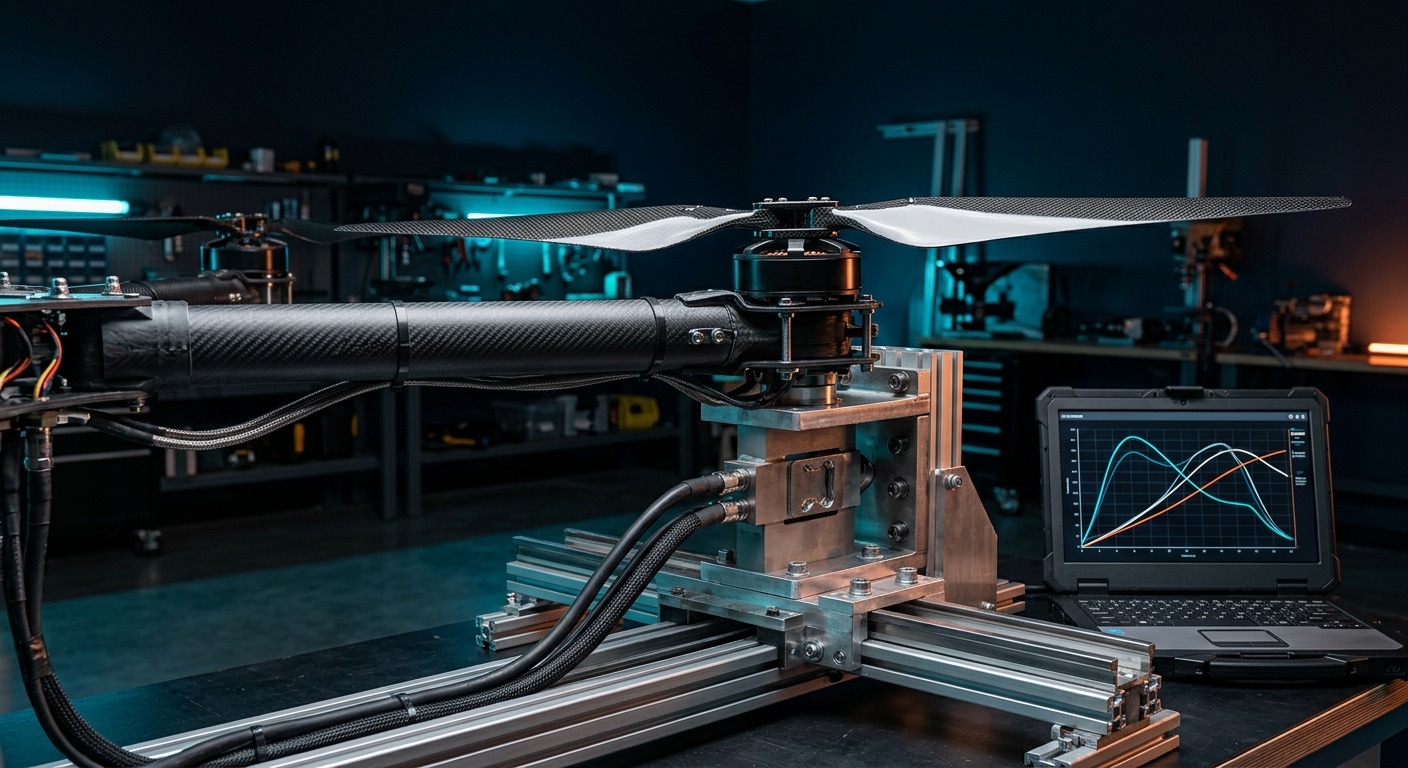
What we do: powertrain calculation and selection for the payload, wiring the flight controller on the frame with a 12S PDB, calibration in the right order (board orientation → accelerometer → level → compass → pre-arm checks), first flight with a reference log, flight analysis by the numbers. On “Gruz H-24” the analysis showed: frame and motors are even in thrust (spread within rotation groups 31–61 µs), while the machine is fighting its own reaction torque — that is mechanics, not something parameters fix. The pilot complained about “not enough thrust”; the real cause of the sluggishness was yaw.
Write to us Describe the task in two lines — we reply to the point.
Other areas of expertise
- Long-range FPV
- Fiber-optic control
- Video pipeline, cameras, goggles
- ArduPilot / INAV / Betaflight
- Reverse engineering of proprietary firmware and formats
- Software to aerospace standards
- Electronics and embedded software
- Series production of UAVs
- Radio reconnaissance
- Cartography and air navigation — the AeroTab projects