ArduPilot / INAV / Betaflight
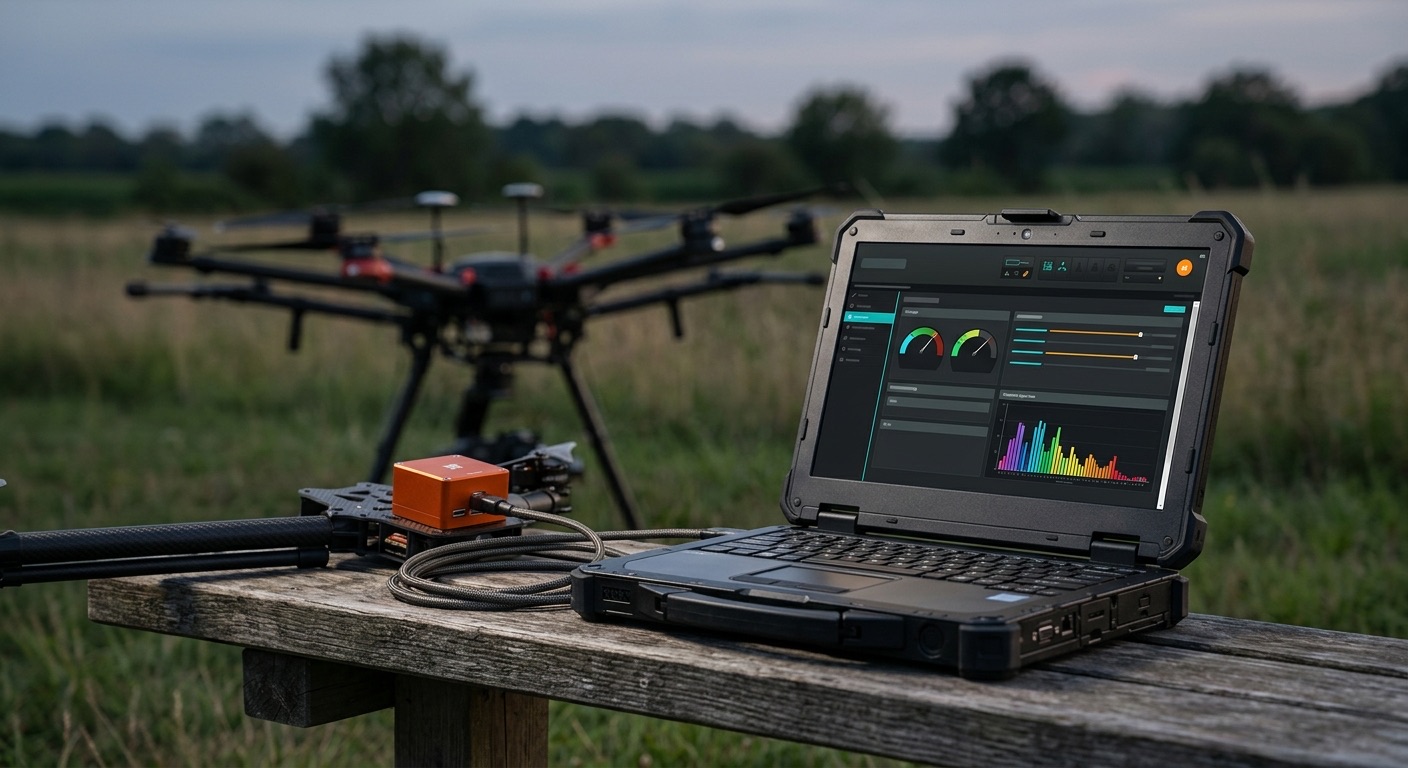
Three flight-controller firmware families, three different tuning cultures. We work in all three and know where each is stronger.
ArduPilot — our choice for heavy and cargo machines. We fly 4.7.1 on CubeOrange+, build the firmware from source with our own features (takeoff guard), run it in SITL with our machine’s physics, and keep passports for 297 boards and 75 frames from the project’s machine-readable sources so the configurator recognizes any aircraft without hard-coded tables.
INAV — we ran a full audit of a heavy hexa on INAV and migrated it to ArduPilot; we know what INAV lacks for the 20″-and-up class (a parameter table by prop) and where it fits: FPV with navigation, return-to-home, waypoint flight on light aircraft.
Betaflight — long-range FPV on 4.5, bird profiles with config transfer between boards, an analog video switch driven by the firmware, a feature-by-feature comparison of our configurator against Betaflight Configurator, and analysis of third-party custom builds on F405 and H743 down to the parameter and the disassembler.
Our own tools that grew out of this work:
- ArduPilot configurator. Everything that normally needs Mission Planner and knowledge of parameter names — as buttons and human words. 26 tabs, about 1,400 parameters with translation and “what it affects” notes, a protected motor test, a one-minute transmitter check wizard, log analysis with charts and a vibration spectrum, PID proposals checked on a digital twin. Windows, macOS, Android (flight controller cabled to the phone), updates arrive by themselves.
- Takeoff guard — three layers of protection against flipping on takeoff: ground-side, Lua on the SD card and C++ inside the ArduPilot firmware; verified on fourteen simulator scenarios including wind gusts and transmitter loss inside the guard window.
- AeroTab GCS — a ground station for the fiber-optic aircraft on protocols we opened and verified: RTP/H.264 video, telemetry and RC as CRSF over UDP, joystick, an aircraft emulator for work without hardware, flight log.
- Fleet server — any configurator or GCS keeps a link to the server: aircraft appear in the registry, a bench can be reached from the internet through a tunnel, logs and aircraft cards upload by themselves. No VPN needed.
- Performance calculator — weight, thrust, TWR, hover throttle, flight time, compatibility check and automatic configuration selection by target parameters.
Write to us Describe the task in two lines — we reply to the point.
Other areas of expertise
- Heavy-lift multirotors on ArduPilot
- Long-range FPV
- Fiber-optic control
- Video pipeline, cameras, goggles
- Reverse engineering of proprietary firmware and formats
- Software to aerospace standards
- Electronics and embedded software
- Series production of UAVs
- Radio reconnaissance
- Cartography and air navigation — the AeroTab projects